Main Menu
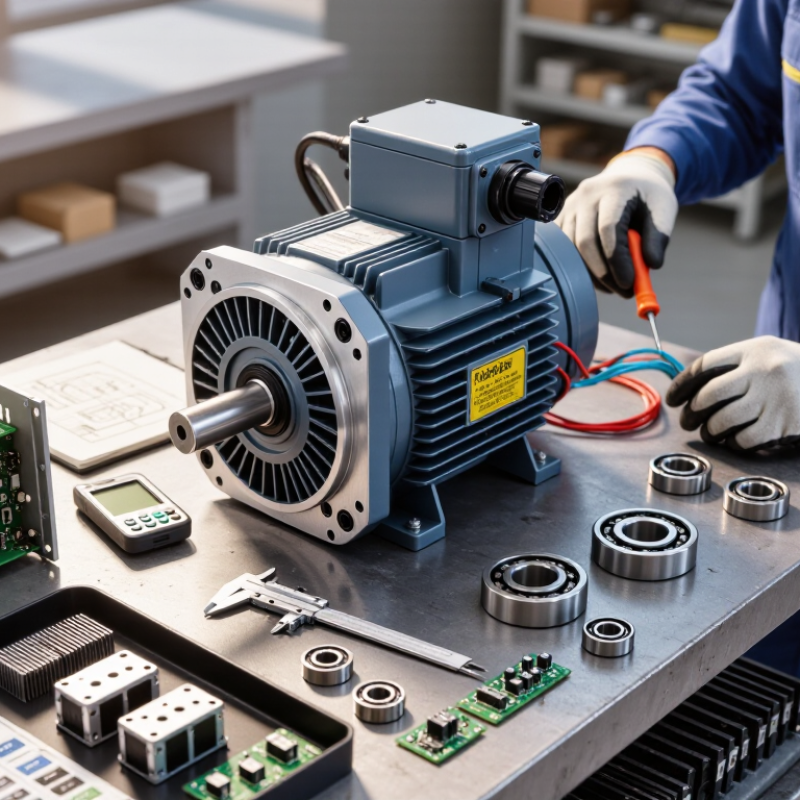
Choosing max motion motors for global sourcing requires more than comparing price, torque, and delivery dates. Buyers must examine the complete motion system. That includes motor type, rated speed, peak torque, encoder accuracy, thermal limits, mounting dimensions, and controller compatibility. A motor that performs well on a test bench may struggle inside a dusty packaging line or a high-cycle robotic joint. Small details matter.
Dr. Kevin Craig, a respected motion-control educator, has said, “Motion control is the integration of mechanics, electronics, and control.” This principle remains highly practical when evaluating max motion motors. A supplier should explain how the motor behaves under continuous load, sudden reversals, vibration, and heat. Request measurable test data, not only attractive catalog claims. Ask for winding specifications, insulation class, bearing life, feedback options, and documented quality procedures. Traceable inspection records also strengthen sourcing decisions.
Global procurement adds another layer of risk. Lead times can shift. Communication can fail. A technically suitable motor may still create problems if replacement parts are unavailable or engineering support is weak. Check sample consistency before approving large volumes. Test several production units, not just one carefully selected sample. That step costs time, but failures cost more.
The selection process is not perfectly predictable. Specifications can hide assumptions. Certifications may not reflect real operating conditions. I would also question suppliers who promise everything immediately. Reliable sourcing depends on evidence, transparent limitations, and a willingness to revise the decision when testing reveals uncomfortable results. Good motors support production. Good judgment protects it.
Choosing motion motors for global sourcing starts with understanding the product range, not comparing prices alone. A typical range may include brushed DC motors, brushless motors, geared motors, stepper motors, and compact servo units. Each type responds differently to load, speed, noise, and control requirements. A geared motor can deliver stronger torque in a small housing. A stepper motor offers precise positioning but may lose torque at higher speeds. Small differences matter.
In supplier reviews, I check rated voltage, continuous torque, peak torque, speed range, duty cycle, and mounting dimensions. I also request drawings, test data, material specifications, and sample units. Do not trust a catalogue alone. Test the motor under realistic conditions, including heat, vibration, repeated starts, and uneven loads. A motor that performs well on a workbench may behave differently inside a packed machine.
Global sourcing adds practical concerns. Confirm wiring standards, packaging quality, replacement parts, lead times, and technical support before placing a large order. Ask whether specifications remain stable between production batches. That question is often overlooked. I once focused too heavily on efficiency and underestimated connector compatibility. The mistake was small, but it delayed assembly. Certification documents should match the final motor configuration, not an older model. Review every detail carefully.
Typical rated power ranges by motor family
AC induction motors generally cover the widest industrial power range, while servo and brushless DC motors are commonly selected for precise motion control and compact equipment. Geared motors combine a motor with speed reduction when higher output torque and lower speed are required. Final sourcing decisions should also verify voltage, frequency, efficiency class, mounting standard, protection rating, duty cycle, certification, and local service support.
The ranges shown are generalized engineering ranges for global product selection and are not manufacturer-specific specifications.
How to Choose Motors for Global Sourcing: Defining Requirements and Application Conditions
A reliable motor decision starts with the machine, not the catalog. Record load torque, speed range, duty cycle, starting frequency, and required positioning accuracy. A conveyor running eight hours daily needs different thermal performance than a robotic actuator making short, repeated moves. Measure the real load if possible. Estimates often hide acceleration peaks.
Energy use deserves early attention. The International Energy Agency reports that electric motor systems consume about 46% of global electricity. The report, Energy-Efficiency Policy Opportunities for Electric Motor-Driven Systems, shows why efficiency and control strategy matter during sourcing. Specify the required efficiency class, inverter compatibility, rated voltage, frequency, and braking method. Also check ambient temperature, dust, humidity, vibration, and installation altitude. Small environmental details can shorten service life.
Think globally, but test locally. Confirm the applicable electrical standards, enclosure rating, certification documents, shaft dimensions, and replacement availability in each destination market. For outdoor equipment, salt exposure may require stronger sealing and corrosion protection. For cold warehouses, lubricant behavior deserves verification. Do not over-specify every feature. That increases cost and may reduce supplier flexibility. Yet choosing only by purchase price is a familiar mistake. A lower-cost motor with poor overload capacity can create expensive downtime. Ask for test records, production tolerances, and sample validation under actual operating conditions. The specification may still be imperfect. Review it after field testing.
| Application Condition | Typical Load Profile | Recommended Motor Type | Typical Supply | Speed Range | Torque or Power Guidance | Duty and Motion Requirements | Environmental Requirements | Control and Feedback | Key Sourcing Checkpoints |
|---|---|---|---|---|---|---|---|---|---|
| Light-Duty Conveyor | Continuous rotation with moderate starting torque and relatively stable load. | Brushless DC motor or AC induction motor with a gear reducer. | 24 VDC, 48 VDC, or 100–240 VAC, depending on the machine architecture. | Motor speed commonly 1,500–3,000 rpm; output speed often 10–200 rpm after reduction. | Approximately 0.5–20 N·m at the geared output for compact conveyors. Confirm using belt force, pulley radius, and acceleration. | S1 continuous duty Allow for frequent starts, stops, and speed changes if the conveyor is indexed. |
IP54 is commonly suitable for clean indoor areas; IP65 is preferable where dust or water spray is present. | Hall sensors for basic speed control; encoder feedback for accurate positioning or synchronization. | Check gearbox service factor, shaft loading, noise level, mounting position, brake requirement, and conveyor safety compliance. |
| Automated Guided Vehicle or Mobile Robot | Repeated acceleration, deceleration, direction changes, and operation from a battery. | Brushless DC servo motor or permanent-magnet synchronous motor with a planetary or spur gearbox. | 24–72 VDC battery systems are common in mobile equipment. | Output wheel speed typically 50–500 rpm, depending on wheel diameter and travel speed. | Approximately 2–60 N·m per drive wheel for small and medium mobile platforms. Include rolling resistance, slope, payload, and acceleration torque. | Intermittent duty with high peak torque. Regenerative braking and thermal cycling must be evaluated. | IP54–IP65 is typical; use sealed connectors and suitable cable protection for floor-level operation. | Incremental encoder, Hall sensors, or absolute encoder for closed-loop speed and odometry control. | Verify battery undervoltage behavior, electromagnetic compatibility, brake release power, connector durability, and CAN or other communication interfaces. |
| Electric Pump | Continuous rotation with torque determined by pump type, pressure, flow, and fluid viscosity. | AC induction motor or brushless motor matched to a fixed-speed or variable-speed drive. | Single-phase or three-phase AC; low-voltage DC is also used in portable systems. | Approximately 1,000–3,600 rpm for many compact pump systems. | Common small-system ratings range from 50 W to 2.2 kW. Pump power should be calculated from pressure, flow, efficiency, and fluid density. | S1 continuous duty Use variable-speed control when flow or pressure must be regulated. |
IP55 or higher for protected industrial locations; select corrosion-resistant materials for humid or chemically exposed areas. | Basic on/off control, analog speed reference, or closed-loop pressure and flow feedback. | Check shaft seal compatibility, maximum fluid temperature, overload protection, priming behavior, vibration, and applicable electrical certifications. |
| Cooling Fan or Blower | Low-to-moderate torque with a strong relationship between speed, airflow, and noise. | External-rotor BLDC motor or AC motor with integrated or external speed control. | 12–48 VDC for compact fans; 100–240 VAC for larger equipment. | Approximately 500–3,000 rpm, depending on impeller design and required airflow. | Usually 10–500 W for compact air-moving equipment; determine operating point from airflow, static pressure, and fan efficiency. | S1 continuous duty Thermal stability and low acoustic noise are often more important than peak torque. |
IP44–IP65 depending on dust, moisture, and installation location; consider elevated ambient temperatures. | Open-loop voltage or PWM control; tachometer output or closed-loop speed feedback for critical cooling. | Compare acoustic performance, bearing life, airflow curve, stall protection, restart behavior, and thermal derating. |
| Robotic Joint or Rotary Actuator | High acceleration, frequent reversals, short positioning cycles, and variable static holding loads. | AC servo or brushless servo motor combined with a precision gearbox. | 48–400 VDC bus systems or 100–240 VAC servo drives are common. | Motor speed commonly 2,000–6,000 rpm; geared output speed may be below 100 rpm. | Continuous torque may range from 1–50 N·m, with peak torque commonly 2–3 times continuous torque for short periods, subject to the motor datasheet. | Intermittent duty with defined acceleration, deceleration, dwell time, and peak torque duration. | IP54–IP65; select higher protection where washdown, dust, or exposed cabling is expected. | High-resolution incremental or absolute encoder; servo drive required for precise position, velocity, and torque control. | Check backlash, torsional stiffness, encoder resolution, peak current, emergency-stop response, brake holding torque, and gearbox life. |
| Linear Actuator for Adjustable Equipment | Short extension and retraction cycles with high axial force and limited travel. | DC geared motor or BLDC motor driving a lead screw or ball screw. | 12, 24, or 48 VDC are common choices. | Motor speed typically 1,000–4,000 rpm; actuator rod speed often 5–100 mm/s. | Typical actuator force ranges from 500 N to 8,000 N. Calculate required force from load, angle, friction, and desired acceleration. | Intermittent duty; many actuators require a rest period to prevent overheating. | IP44–IP66 depending on indoor, medical, agricultural, or outdoor use. | Limit switches for end-of-travel protection; Hall sensors or encoder feedback for position control. | Verify screw efficiency, self-locking behavior, static load rating, duty-cycle limits, noise, anti-pinch protection, and mechanical end stops. |
| Outdoor Gate, Door, or Barrier | Low-speed movement with high breakaway torque, holding load, and exposure to weather. | Geared DC motor, BLDC motor, or AC motor with an electromagnetic brake. | 24 VDC, 48 VDC, or 100–240 VAC depending on gate size and control cabinet design. | Output speed commonly 5–100 rpm or a linear movement of approximately 50–300 mm/s. | Approximately 5–150 N·m at the output shaft for compact and medium mechanisms; calculate from gate mass, friction, slope, and wind load. | Intermittent duty with repeated opening and closing cycles; include a safe manual-release method. | IP65 or higher is often appropriate; consider UV exposure, condensation, corrosion, and temperatures from approximately −20 °C to 50 °C. | Limit switches, magnetic sensors, encoders, obstruction detection, and controlled braking are commonly used. | Confirm regional electrical safety requirements, emergency release, anti-crush protection, corrosion resistance, and cold-start performance. |
| Precision Positioning Stage | Low backlash, repeatable movement, controlled acceleration, and stable positioning under changing loads. | Servo motor or two-phase stepper motor with a precision transmission. | 24–80 VDC for compact stages; higher-voltage servo buses are used in larger systems. | Approximately 100–4,000 rpm, depending on lead pitch, travel speed, and required resolution. | Typical motor torque ranges from 0.1–10 N·m. Select based on reflected inertia, acceleration, friction, and vertical-axis holding force. | Intermittent or continuous motion; resonance, settling time, and thermal drift must be assessed. | IP40–IP54 for clean indoor equipment; use higher protection for dust or coolant exposure. | Encoder feedback for servo systems; open-loop or closed-loop stepper control for selected applications. | Check repeatability, resolution, backlash, runout, bearing preload, vibration, homing accuracy, and drive tuning compatibility. |
| Industrial Mixer or Agitator | High starting torque, variable viscosity, and possible shock loads during material changes. | Three-phase induction motor or high-torque BLDC motor with a helical, planetary, or worm gearbox. | 200–480 VAC three-phase is common in industrial installations. | Output speed commonly 10–300 rpm. | Approximately 20–1,000 N·m at the geared output, depending on batch size, viscosity, impeller geometry, and required mixing time. | S1 continuous duty Allow for high transient torque and possible overload during start-up. |
IP55–IP66; select suitable shaft seals and materials for washdown, dust, or corrosive process environments. | Variable-frequency drive with overload monitoring; speed feedback may be required for process consistency. | Verify service factor, gearbox thermal rating, shaft and bearing loads, sanitary or hazardous-area requirements, and process temperature. |
| Selection note: Before global sourcing, document rated voltage, continuous and peak torque, speed range, duty cycle, load inertia, mounting dimensions, shaft geometry, feedback type, brake requirements, ambient conditions, ingress protection, expected service life, and required certifications. Final motor sizing should be confirmed using the complete load profile and the supplier’s tested performance data. | |||||||||
When sourcing motion motors globally, evaluate performance under real operating conditions, not catalogue speed alone. In factory trials, I measure startup torque, speed stability, heat rise, vibration, and noise. A motor may meet rated output yet stall when a loaded axis changes direction. Ask for test curves at your voltage, duty cycle, and ambient temperature. Small details matter. Confirm encoder resolution, braking response, and positioning repeatability. Request sample data, not promises.
Quality depends on traceable materials, winding consistency, bearing selection, and end-of-line inspection. Reliable suppliers should explain sampling plans, failure records, corrective actions, and production controls. I prefer witnessed testing for early batches, although this can slow purchasing. That delay is often useful. Check connector pinouts, mounting dimensions, shaft tolerances, controller protocols, and cable length before approval. A technically strong motor can still fail integration. Voltage and current limits must match the drive, especially during acceleration. Certifications should be verified for the destination market.
Tips: Build a comparison sheet with measured values. Test at minimum and maximum loads. Keep two samples for review. Ask what happens after 2,000 hours. Do not ignore awkward answers. If a supplier cannot provide clear drawings or repeatable test records, pause the order. Document one unresolved risk instead of pretending the evaluation is complete.
Choosing motors for global sourcing requires more than comparing unit prices. A low quote can hide tooling, inspection, packaging, and replacement costs. In practical sourcing reviews, freight estimates often change after carton dimensions are confirmed. Request a landed-cost sheet for each destination. Include motor price, payment fees, duties, insurance, inland delivery, and expected warranty claims. Use realistic order volumes, not optimistic forecasts. Small details matter. A 2.5-kilogram motor may need stronger foam and a larger shipping class.
Compliance should be checked before supplier selection, not after production. Ask for test reports, declarations, material records, and traceable model numbers. Confirm whether the destination requires electrical safety, electromagnetic compatibility, energy, or restricted-substance controls. Documents should match the shipped motor exactly. A certificate for a similar model is not enough. Use an independent laboratory when claims appear unclear. Keep revision dates and batch records. Regulations differ by market. Treat compliance as a cost and schedule item, not paperwork.
Logistics planning should connect motor design with delivery conditions. Confirm voltage, frequency, shaft dimensions, connectors, and operating temperature before ordering samples. A mismatch can create an expensive return, especially across borders. Ask for lead times during normal and peak capacity. Build buffer days for port congestion and customs review. Choose packaging that prevents shaft impact and moisture damage. Sea freight may reduce cost, but urgent replenishment can favor air shipment. That trade-off deserves calculation. My sourcing assumptions would need review when demand is volatile. Pilot orders, inspection checkpoints, and clear acceptance criteria provide stronger evidence than email promises.
Choosing the right motion motor supplier requires more than comparing unit prices. Start with the machine’s actual workload, not an ideal laboratory figure. Check continuous torque, peak torque, speed range, duty cycle, voltage, mounting dimensions, and operating temperature. A motor that looks efficient on paper may overheat beside a dusty conveyor.
Ask each supplier for dated test reports, dimensional drawings, material specifications, and production tolerances. Useful suppliers explain how they measure noise, vibration, winding resistance, and thermal rise. Request samples from normal production, not specially prepared units. Test them under your real load.
Compare minimum order quantities, lead times, packaging, spare-part access, and communication speed. A lower quotation can become expensive when replacement shafts arrive late. Review factory audits, quality records, traceability systems, and independent certifications relevant to your market. Also confirm whether the supplier can maintain the same winding design across repeat orders.
Do not rely only on a polished catalogue. Speak with the engineering team about overload protection, controller compatibility, and failed-sample analysis. Their answers often reveal practical competence. One weakness in my own evaluations has been giving too much weight to price and too little to after-sales response. A supplier that admits design limits may be safer than one promising everything. Build a comparison sheet, score evidence rather than claims, and leave room for pilot testing before committing to global volume.
Office: (281) 855-2218
Copyright © 2025 Telco Intercontinental Corp. All rights reserved. Privacy Policy | Legal Disclaimer
Telco®, TelcoMotion®, and TelcoGreen® are registered trademarks of Telco Intercontinental Corp.